MVD > How to Decide Whether a Press Brake Part Is Suitable for Robotic Bending?

How to Decide Whether a Press Brake Part Is Suitable for Robotic Bending?

Robotic bending is not only a question of whether the press brake can produce the specified bends. Press brake part suitability for robotic bending depends on whether the cell can manage a controlled sequence from blank pickup through finished-part placement. A part may be feasible to form while still presenting handling issues for automation. In particular, parts that are difficult to grip and stack robotically can remain practical to form manually. For a robotic press brake cell, the relevant handling and forming conditions must be controlled and validated throughout the process. The most useful review examines the full route rather than an isolated bend. The cell must establish a known part position, orientation, grip condition, clearance, and process state; present the workpiece consistently for each bend; maintain access as geometry changes; and remove the completed part using a dependable stacking or placement method. Material response, programming effort, and production-run characteristics also affect the decision. Evaluate Robotic Bending Feasibility Through the End-to-End Process Flow Begin with a demanding question: can the cell maintain a known position, orientation, grip condition, clearance, and process state from blank pickup through acceptance of the formed part? This is broader than confirming that a robot can reach the press brake. A reachable part may still require further development if its grip condition or orientation cannot be maintained through a regrip, if a formed flange blocks a later grip point, or if the completed geometry has no dependable removal and stacking plan. Mapping the sequence makes these dependencies visible before extensive programming begins. A grip point available on a flat blank can become inaccessible after a flange is formed. A bend order that works from a tooling perspective can also change the available approach paths, support requirements, and access for the next handling move. For screening, define each transition in the part journey: blank stack to single-blank pickup; pickup to the first locating position; each bend to the next handling orientation or regrip; final bend to finished-part removal; and removal to stacking or placement. The assessment should address the entire connected sequence. A digitally reachable move is only one part of a production-ready handling plan. Differentiate Sheet Separation from Mere Stack-Top Detection Blank separation requires its own review. Thin blanks can adhere to one another because of oil film, static attraction, burrs, or nesting. Measuring stack height can identify the top of a stack, but it does not establish that the robot has picked exactly one blank. For unattended loading, the cell must distinguish a confirmed single-sheet pickup from an uncertain pickup. If pickup is uncertain, the initial workpiece condition remains unverified and must be resolved before the process proceeds. The expected pickup location alone is not sufficient evidence that the correct blank condition has been established.   This distinction belongs at the start of robotic bending part screening because every subsequent operation assumes that the cell is handling the intended workpiece. Reliable automation begins with a verified blank rather than an inferred one. Assess gripping and locating in the robotic press brake cell The robot does not replace the geometric reference provided by the backgauge. The backgauge establishes the bend reference, while the robot presents and supports the workpiece. Robot repeatability therefore cannot correct inconsistent seating against the backgauge. A suitable part must allow repeatable presentation at each gauging step. Review whether the gripper can hold the workpiece securely while allowing the required orientation at the backgauge, and whether the part can be supported without interfering with seating. The issue is not simply whether the robot can carry the blank to the machine. It is whether the workpiece can arrive at the same geometric reference in a repeatable condition. Gripping needs can change as bends accumulate. Interior cutouts and bend locations can force gripper repositioning between bends. This does not automatically exclude automation, but it turns the process into a regripping assessment rather than a straightforward pick-and-hold task. Evaluate Release-and-Regrip Moves as Physical Events In-machine regripping can be demanding for larger parts. If a clamped workpiece is released to change grip points, a flange can deflect under its own weight. In the described larger-part case, that deflection impaired later positioning and bend accuracy. Where this condition must be managed, a separate regripping station may be required instead of a release-and-regrip move within the press brake. The key point is that a regrip is not only a programmed motion. It is also a change in the physical support condition of the workpiece. Payload review belongs in the same analysis. It must include the combined mass of the workpiece and gripper. For large blanks, distributed mass creates a moment arm that can reduce the robot's effective payload capability. Screening based on blank weight alone can therefore overlook an important handling constraint. Check robotic bending tooling access through every bend Tooling for automated bending has two connected purposes: it must form the required geometry and permit safe robot and gripper access. Punch height, die width, segmentation, and adjacent tool locations can determine whether the robot wrist and gripper can approach, support, and withdraw safely. Review these factors against the changing part shape, not only the flat blank. As flanges are formed, they can restrict approach paths, occupy space needed by the gripper, or block a grip point that was available earlier in the sequence. Tooling access and bend order should therefore be assessed together. If the selected order prevents later handling, the process may need a different bend sequence, tooling layout, grip point, or planned regrip. Each alternative then needs to be checked again for clearance, support, and repeatable gauging. A practical review asks whether the robot can perform the following at every stage: approach the workpiece; hold it without obstructing the forming operation; support it as required; withdraw clear of the tooling after the bend; and reach the next handling position without a potential collision. Offline simulation can assess bend order, robot reach, tooling access, regrips, and potential collisions before production. It is valuable for identifying conflicts early, but a feasible simulated path does not alone establish reliable production. Physical variation in blank presentation, gripping, locating, material behavior, and formed geometry still requires control and validation. Include material response in press brake part suitability Geometry is only one part of the forming assessment. Material type, thickness, bend length, grain direction, bend radius, flange size, angular tolerance, and production quantity jointly affect usable capacity and repeatable production. This combined review matters because a machine that forms one acceptable sample may not safely or consistently produce a full batch. Material behavior affects released angle and formed geometry, both of which should be validated against later clearance, grip access, and locating requirements in the robotic sequence. Tight bend radii can raise cracking risk. Springback can require controlled overbending to achieve the specified released angle. Grain direction can influence cracking, springback, and radius requirements. These effects do not create a universal pass-or-fail rule; they must be validated for the intended material and process. For robotic bending, material validation should not be treated as a separate capacity exercise. If released geometry varies, a later movement may need renewed validation for clearance, grip access, or seating against the backgauge. Connecting material and bend requirements to the handling plan produces a more complete suitability decision. Evaluate finished-part stacking before approving automation Finished-part stackability is a separate screen from bend feasibility. A component can be feasible to bend but difficult for a robot to grip and stack. Such a part may still be practical to form manually. Unusual finished shapes can require special gripping and nested stacking. These methods can provide a workable strategy, but they add programming effort and should be included in the assessment from the start. The central question is whether the robot can grip, remove, and stack or place the finished part dependably. A workable bend sequence is incomplete until the cell also has a dependable finished-part handling method. Early review helps align decisions across the process. The grip strategy selected for tool access may not suit part removal, while the orientation that supports the final bend may require a different stacking arrangement. Considering discharge alongside bend order, tooling, and gripping reveals these relationships before the process is finalized. Balance press brake automation economics with run characteristics Technical feasibility and economic suitability are related but distinct findings. Challenging parts can require special tools, gripping arrangements, or nested stacking, increasing programming time. That effort remains an important input to an automate-or-not decision. Production quantity also remains relevant. Tool and gripper changes can support smaller lots, while longer runs are reported to achieve the highest efficiencies. This does not establish a universal minimum batch size. The appropriate decision depends on the part's handling complexity, the required programming effort, and the characteristics of the production run. A part may be technically automatable yet economically weak for a short, demanding run. Another may have a relatively straightforward and repeatable handling sequence that supports the programming effort over a longer run. Keeping technical and economic conclusions separate prevents a handling issue from being misidentified as a run-length issue, or vice versa. Make the decision from sequence reliability, not bend feasibility A sound decision on press brake part suitability for robotic bending follows the complete part journey. The cell must reliably isolate one blank, establish and retain a known grip and orientation, seat the workpiece consistently against the backgauge, maintain tooling access, validate material-driven behavior, and remove and stack the completed component dependably. Offline simulation is an important part of that work, particularly for reach, collisions, bend order, tooling access, and regrips. Yet simulation must be followed by validation of the physical conditions that affect production reliability. The governing discipline is to screen the part as a connected handling-and-forming sequence. When blank pickup, gripping, locating, tooling access, material response, finished-part stacking, programming effort, and run characteristics support the same process plan, the part has a credible basis for repeatable automated production.
How to Decide Whether a Press Brake Part Is Suitable for Robotic Bending?

How to Decide Whether a Press Brake Part Is Suitable for Robotic Bending?

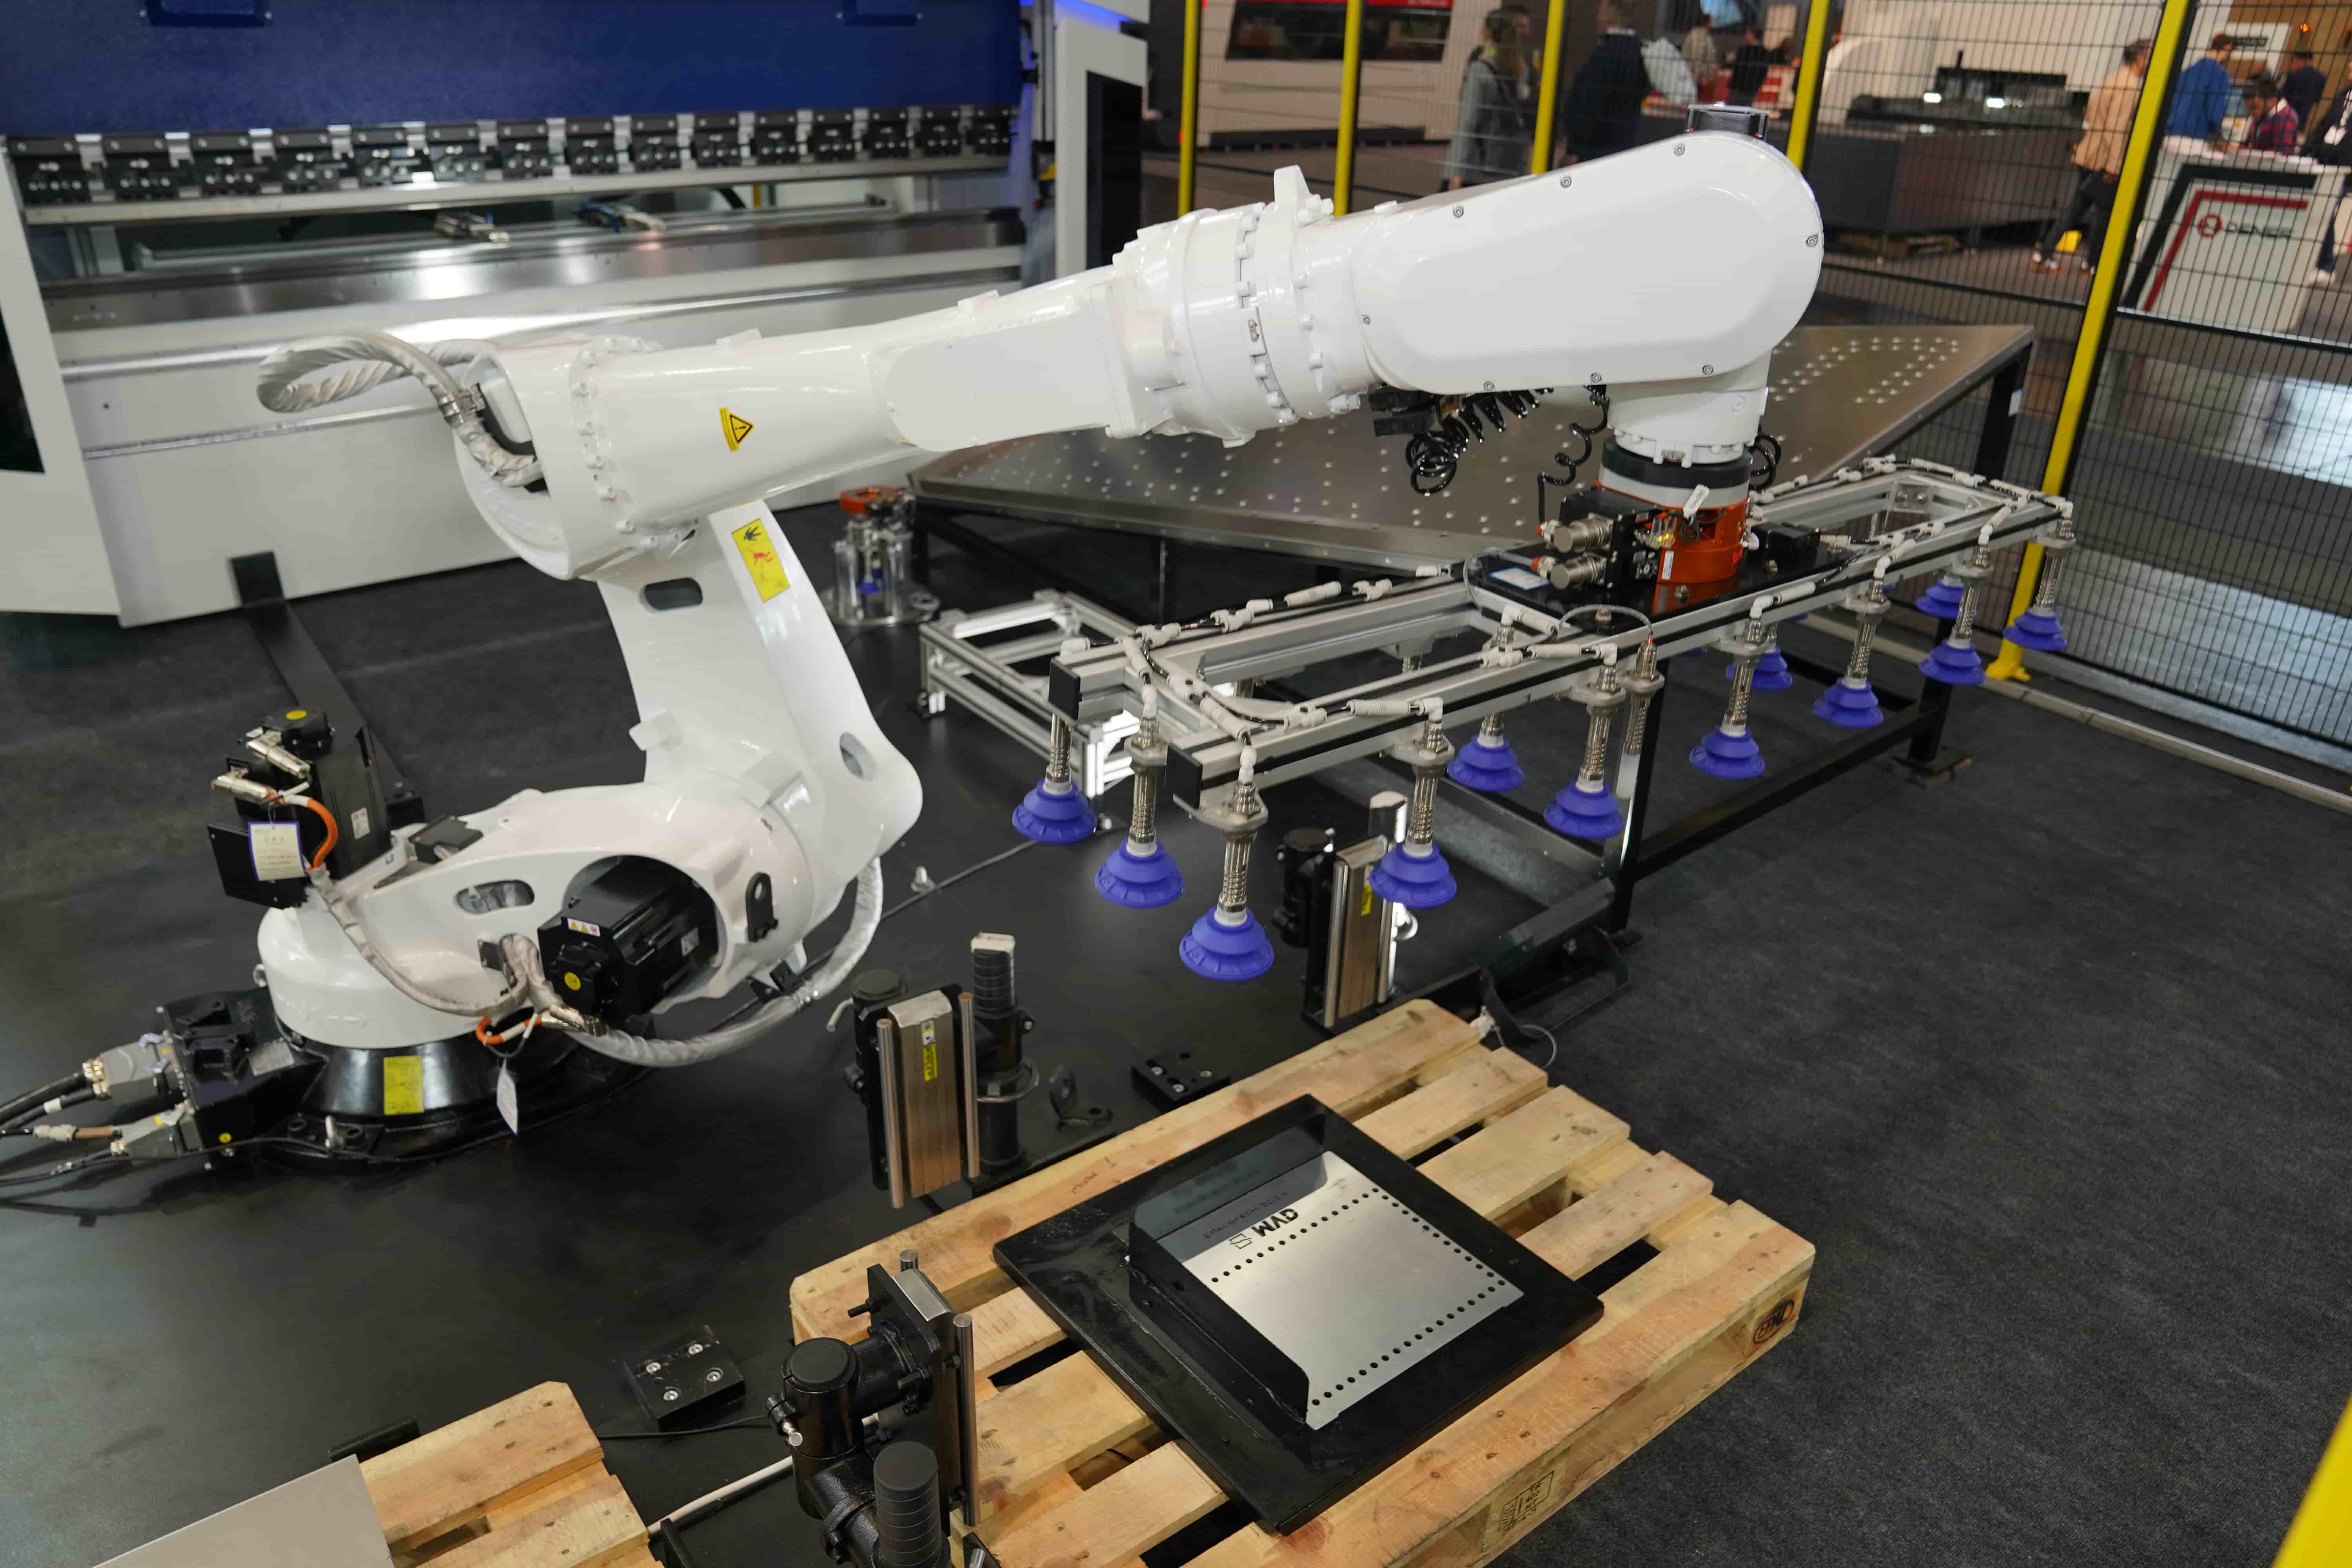
Robotic bending is not only a question of whether the press brake can produce the specified bends. Press brake part suitability for robotic bending depends on whether the cell can manage a controlled sequence from blank pickup through finished-part placement.

A part may be feasible to form while still presenting handling issues for automation. In particular, parts that are difficult to grip and stack robotically can remain practical to form manually. For a robotic press brake cell, the relevant handling and forming conditions must be controlled and validated throughout the process.

The most useful review examines the full route rather than an isolated bend. The cell must establish a known part position, orientation, grip condition, clearance, and process state; present the workpiece consistently for each bend; maintain access as geometry changes; and remove the completed part using a dependable stacking or placement method. Material response, programming effort, and production-run characteristics also affect the decision.

Evaluate Robotic Bending Feasibility Through the End-to-End Process Flow

Begin with a demanding question: can the cell maintain a known position, orientation, grip condition, clearance, and process state from blank pickup through acceptance of the formed part?

This is broader than confirming that a robot can reach the press brake. A reachable part may still require further development if its grip condition or orientation cannot be maintained through a regrip, if a formed flange blocks a later grip point, or if the completed geometry has no dependable removal and stacking plan.

Mapping the sequence makes these dependencies visible before extensive programming begins. A grip point available on a flat blank can become inaccessible after a flange is formed. A bend order that works from a tooling perspective can also change the available approach paths, support requirements, and access for the next handling move.

For screening, define each transition in the part journey:

  • blank stack to single-blank pickup;
  • pickup to the first locating position;
  • each bend to the next handling orientation or regrip;
  • final bend to finished-part removal; and
  • removal to stacking or placement.

The assessment should address the entire connected sequence. A digitally reachable move is only one part of a production-ready handling plan.

Differentiate Sheet Separation from Mere Stack-Top Detection

Blank separation requires its own review. Thin blanks can adhere to one another because of oil film, static attraction, burrs, or nesting. Measuring stack height can identify the top of a stack, but it does not establish that the robot has picked exactly one blank.

For unattended loading, the cell must distinguish a confirmed single-sheet pickup from an uncertain pickup. If pickup is uncertain, the initial workpiece condition remains unverified and must be resolved before the process proceeds. The expected pickup location alone is not sufficient evidence that the correct blank condition has been established. 

 This distinction belongs at the start of robotic bending part screening because every subsequent operation assumes that the cell is handling the intended workpiece. Reliable automation begins with a verified blank rather than an inferred one.

Assess gripping and locating in the robotic press brake cell

The robot does not replace the geometric reference provided by the backgauge. The backgauge establishes the bend reference, while the robot presents and supports the workpiece. Robot repeatability therefore cannot correct inconsistent seating against the backgauge.

A suitable part must allow repeatable presentation at each gauging step. Review whether the gripper can hold the workpiece securely while allowing the required orientation at the backgauge, and whether the part can be supported without interfering with seating. The issue is not simply whether the robot can carry the blank to the machine. It is whether the workpiece can arrive at the same geometric reference in a repeatable condition.

Gripping needs can change as bends accumulate. Interior cutouts and bend locations can force gripper repositioning between bends. This does not automatically exclude automation, but it turns the process into a regripping assessment rather than a straightforward pick-and-hold task.

Evaluate Release-and-Regrip Moves as Physical Events

In-machine regripping can be demanding for larger parts. If a clamped workpiece is released to change grip points, a flange can deflect under its own weight. In the described larger-part case, that deflection impaired later positioning and bend accuracy.

Where this condition must be managed, a separate regripping station may be required instead of a release-and-regrip move within the press brake. The key point is that a regrip is not only a programmed motion. It is also a change in the physical support condition of the workpiece.

Payload review belongs in the same analysis. It must include the combined mass of the workpiece and gripper. For large blanks, distributed mass creates a moment arm that can reduce the robot's effective payload capability. Screening based on blank weight alone can therefore overlook an important handling constraint.

Check robotic bending tooling access through every bend

Tooling for automated bending has two connected purposes: it must form the required geometry and permit safe robot and gripper access. Punch height, die width, segmentation, and adjacent tool locations can determine whether the robot wrist and gripper can approach, support, and withdraw safely.

Review these factors against the changing part shape, not only the flat blank. As flanges are formed, they can restrict approach paths, occupy space needed by the gripper, or block a grip point that was available earlier in the sequence.

Tooling access and bend order should therefore be assessed together. If the selected order prevents later handling, the process may need a different bend sequence, tooling layout, grip point, or planned regrip. Each alternative then needs to be checked again for clearance, support, and repeatable gauging.

A practical review asks whether the robot can perform the following at every stage:

  • approach the workpiece;
  • hold it without obstructing the forming operation;
  • support it as required;
  • withdraw clear of the tooling after the bend;
  • and reach the next handling position without a potential collision.

Offline simulation can assess bend order, robot reach, tooling access, regrips, and potential collisions before production. It is valuable for identifying conflicts early, but a feasible simulated path does not alone establish reliable production. Physical variation in blank presentation, gripping, locating, material behavior, and formed geometry still requires control and validation.

Include material response in press brake part suitability

Geometry is only one part of the forming assessment. Material type, thickness, bend length, grain direction, bend radius, flange size, angular tolerance, and production quantity jointly affect usable capacity and repeatable production.

This combined review matters because a machine that forms one acceptable sample may not safely or consistently produce a full batch. Material behavior affects released angle and formed geometry, both of which should be validated against later clearance, grip access, and locating requirements in the robotic sequence.

Tight bend radii can raise cracking risk. Springback can require controlled overbending to achieve the specified released angle. Grain direction can influence cracking, springback, and radius requirements. These effects do not create a universal pass-or-fail rule; they must be validated for the intended material and process.

For robotic bending, material validation should not be treated as a separate capacity exercise. If released geometry varies, a later movement may need renewed validation for clearance, grip access, or seating against the backgauge. Connecting material and bend requirements to the handling plan produces a more complete suitability decision.

Evaluate finished-part stacking before approving automation

Finished-part stackability is a separate screen from bend feasibility. A component can be feasible to bend but difficult for a robot to grip and stack. Such a part may still be practical to form manually.

Unusual finished shapes can require special gripping and nested stacking. These methods can provide a workable strategy, but they add programming effort and should be included in the assessment from the start.

The central question is whether the robot can grip, remove, and stack or place the finished part dependably. A workable bend sequence is incomplete until the cell also has a dependable finished-part handling method.

Early review helps align decisions across the process. The grip strategy selected for tool access may not suit part removal, while the orientation that supports the final bend may require a different stacking arrangement. Considering discharge alongside bend order, tooling, and gripping reveals these relationships before the process is finalized.

Balance press brake automation economics with run characteristics

Technical feasibility and economic suitability are related but distinct findings. Challenging parts can require special tools, gripping arrangements, or nested stacking, increasing programming time. That effort remains an important input to an automate-or-not decision.

Production quantity also remains relevant. Tool and gripper changes can support smaller lots, while longer runs are reported to achieve the highest efficiencies. This does not establish a universal minimum batch size. The appropriate decision depends on the part's handling complexity, the required programming effort, and the characteristics of the production run.

A part may be technically automatable yet economically weak for a short, demanding run. Another may have a relatively straightforward and repeatable handling sequence that supports the programming effort over a longer run. Keeping technical and economic conclusions separate prevents a handling issue from being misidentified as a run-length issue, or vice versa.

Make the decision from sequence reliability, not bend feasibility

A sound decision on press brake part suitability for robotic bending follows the complete part journey. The cell must reliably isolate one blank, establish and retain a known grip and orientation, seat the workpiece consistently against the backgauge, maintain tooling access, validate material-driven behavior, and remove and stack the completed component dependably.

Offline simulation is an important part of that work, particularly for reach, collisions, bend order, tooling access, and regrips. Yet simulation must be followed by validation of the physical conditions that affect production reliability.

The governing discipline is to screen the part as a connected handling-and-forming sequence. When blank pickup, gripping, locating, tooling access, material response, finished-part stacking, programming effort, and run characteristics support the same process plan, the part has a credible basis for repeatable automated production.


MVD Team MVD Team - 20 August 2026
Share